
Project case study · Hardware design
FC_H743 / Flight Controller
A flight controller designed for a flexible UAV platform.
FC_H743 is an open-source flight controller design by Minh An / AniTech. It combines STM32H743 processing, dual inertial sensors, Blackbox storage and expansion ports for modern flight systems.
Hardware design published
The repository includes schematics, layout, Gerbers, BOM and pick-and-place files. Assembly and flight-test results have not been published.
STM32H743
ARM Cortex-M7 · 480 MHz
2 × BMI088
Independent IMUs + SPL06-001
4 layers
50 × 45 mm · KiCad 10
3S–6S
LiPo · 10–30 V
01 / Design challenge
Bringing control, sensing and connectivity together on a compact board.
The design has to accommodate a fast processor, two independent IMUs, onboard logging and multiple interfaces while retaining a 30.5 × 30.5 mm mounting pattern. Component placement, power distribution and routing all matter on a four-layer PCB.
02 / Engineering approach
From schematic to fabrication-ready files.
Processing architecture
STM32H743VIH6, two Bosch BMI088 sensors on separate SPI buses and an SPL06-001 barometer.
Power & interfaces
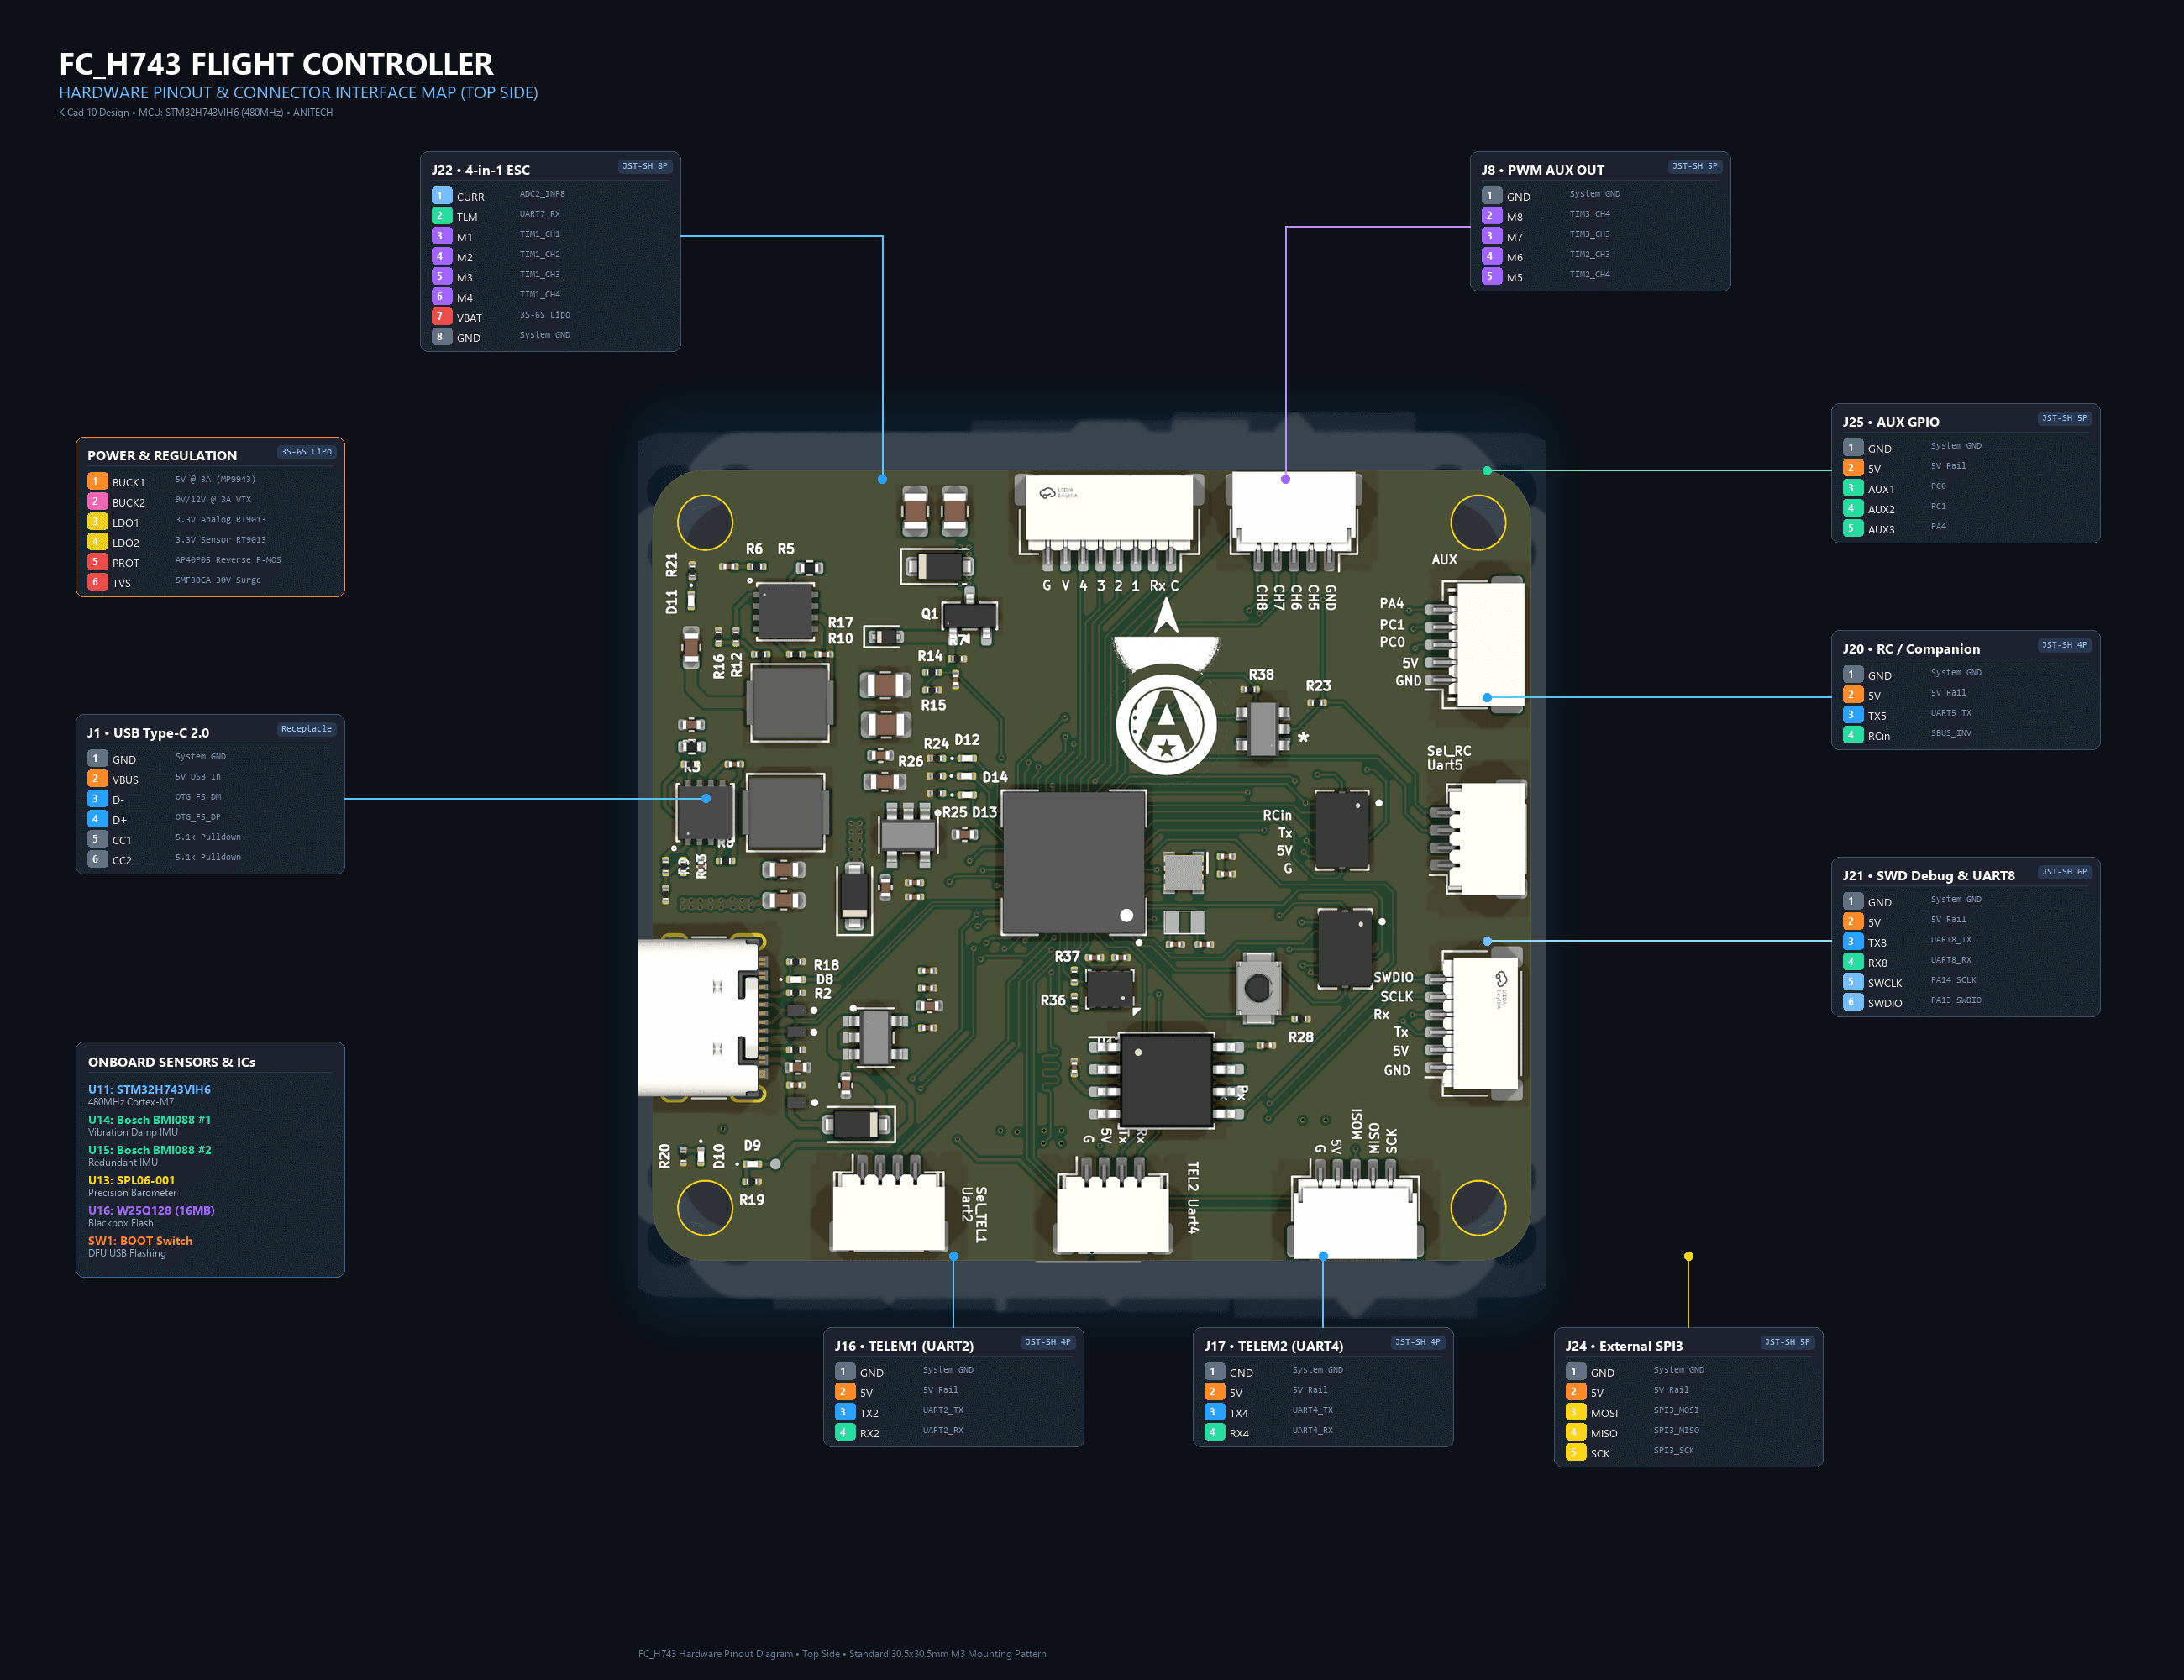
5 V and 9/12 V buck rails, dedicated sensor LDOs; USB-C, GPS, ESC, UART and SWD.
Fabrication package
Four-layer PCB, schematic, Gerber/Drill files, BOM and pick-and-place coordinates published in the repo.
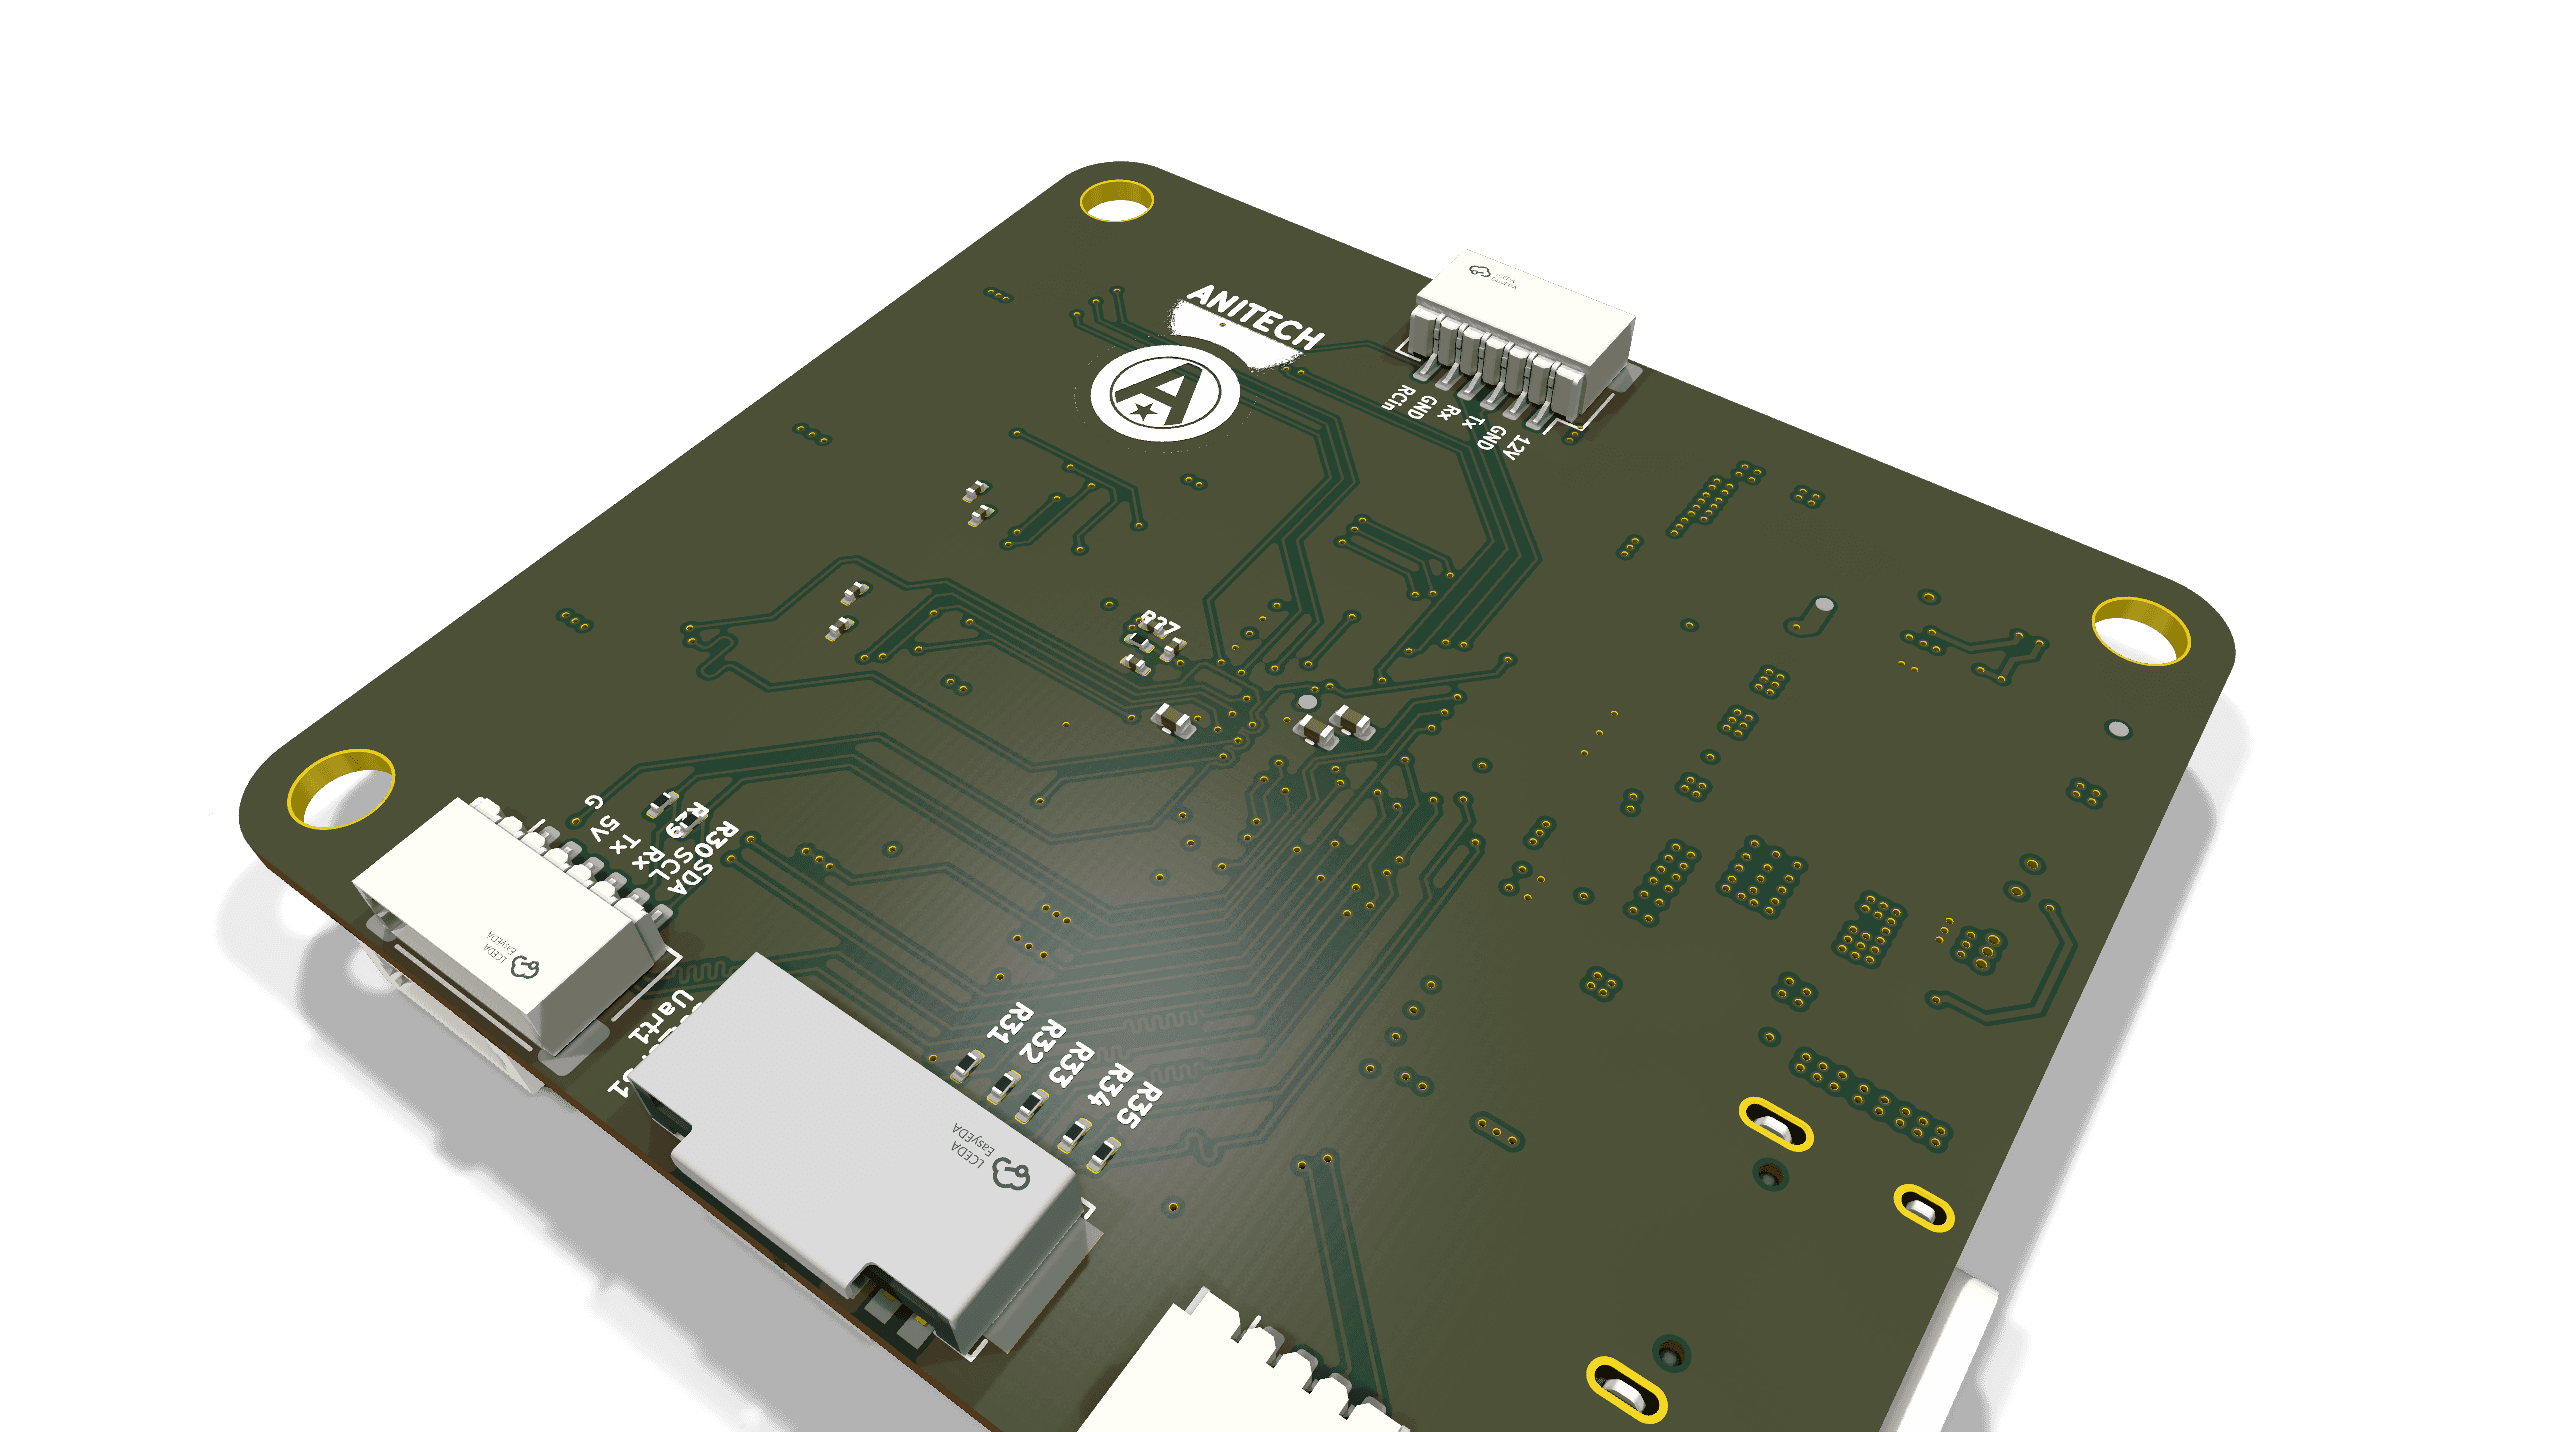
03 / Design close-up
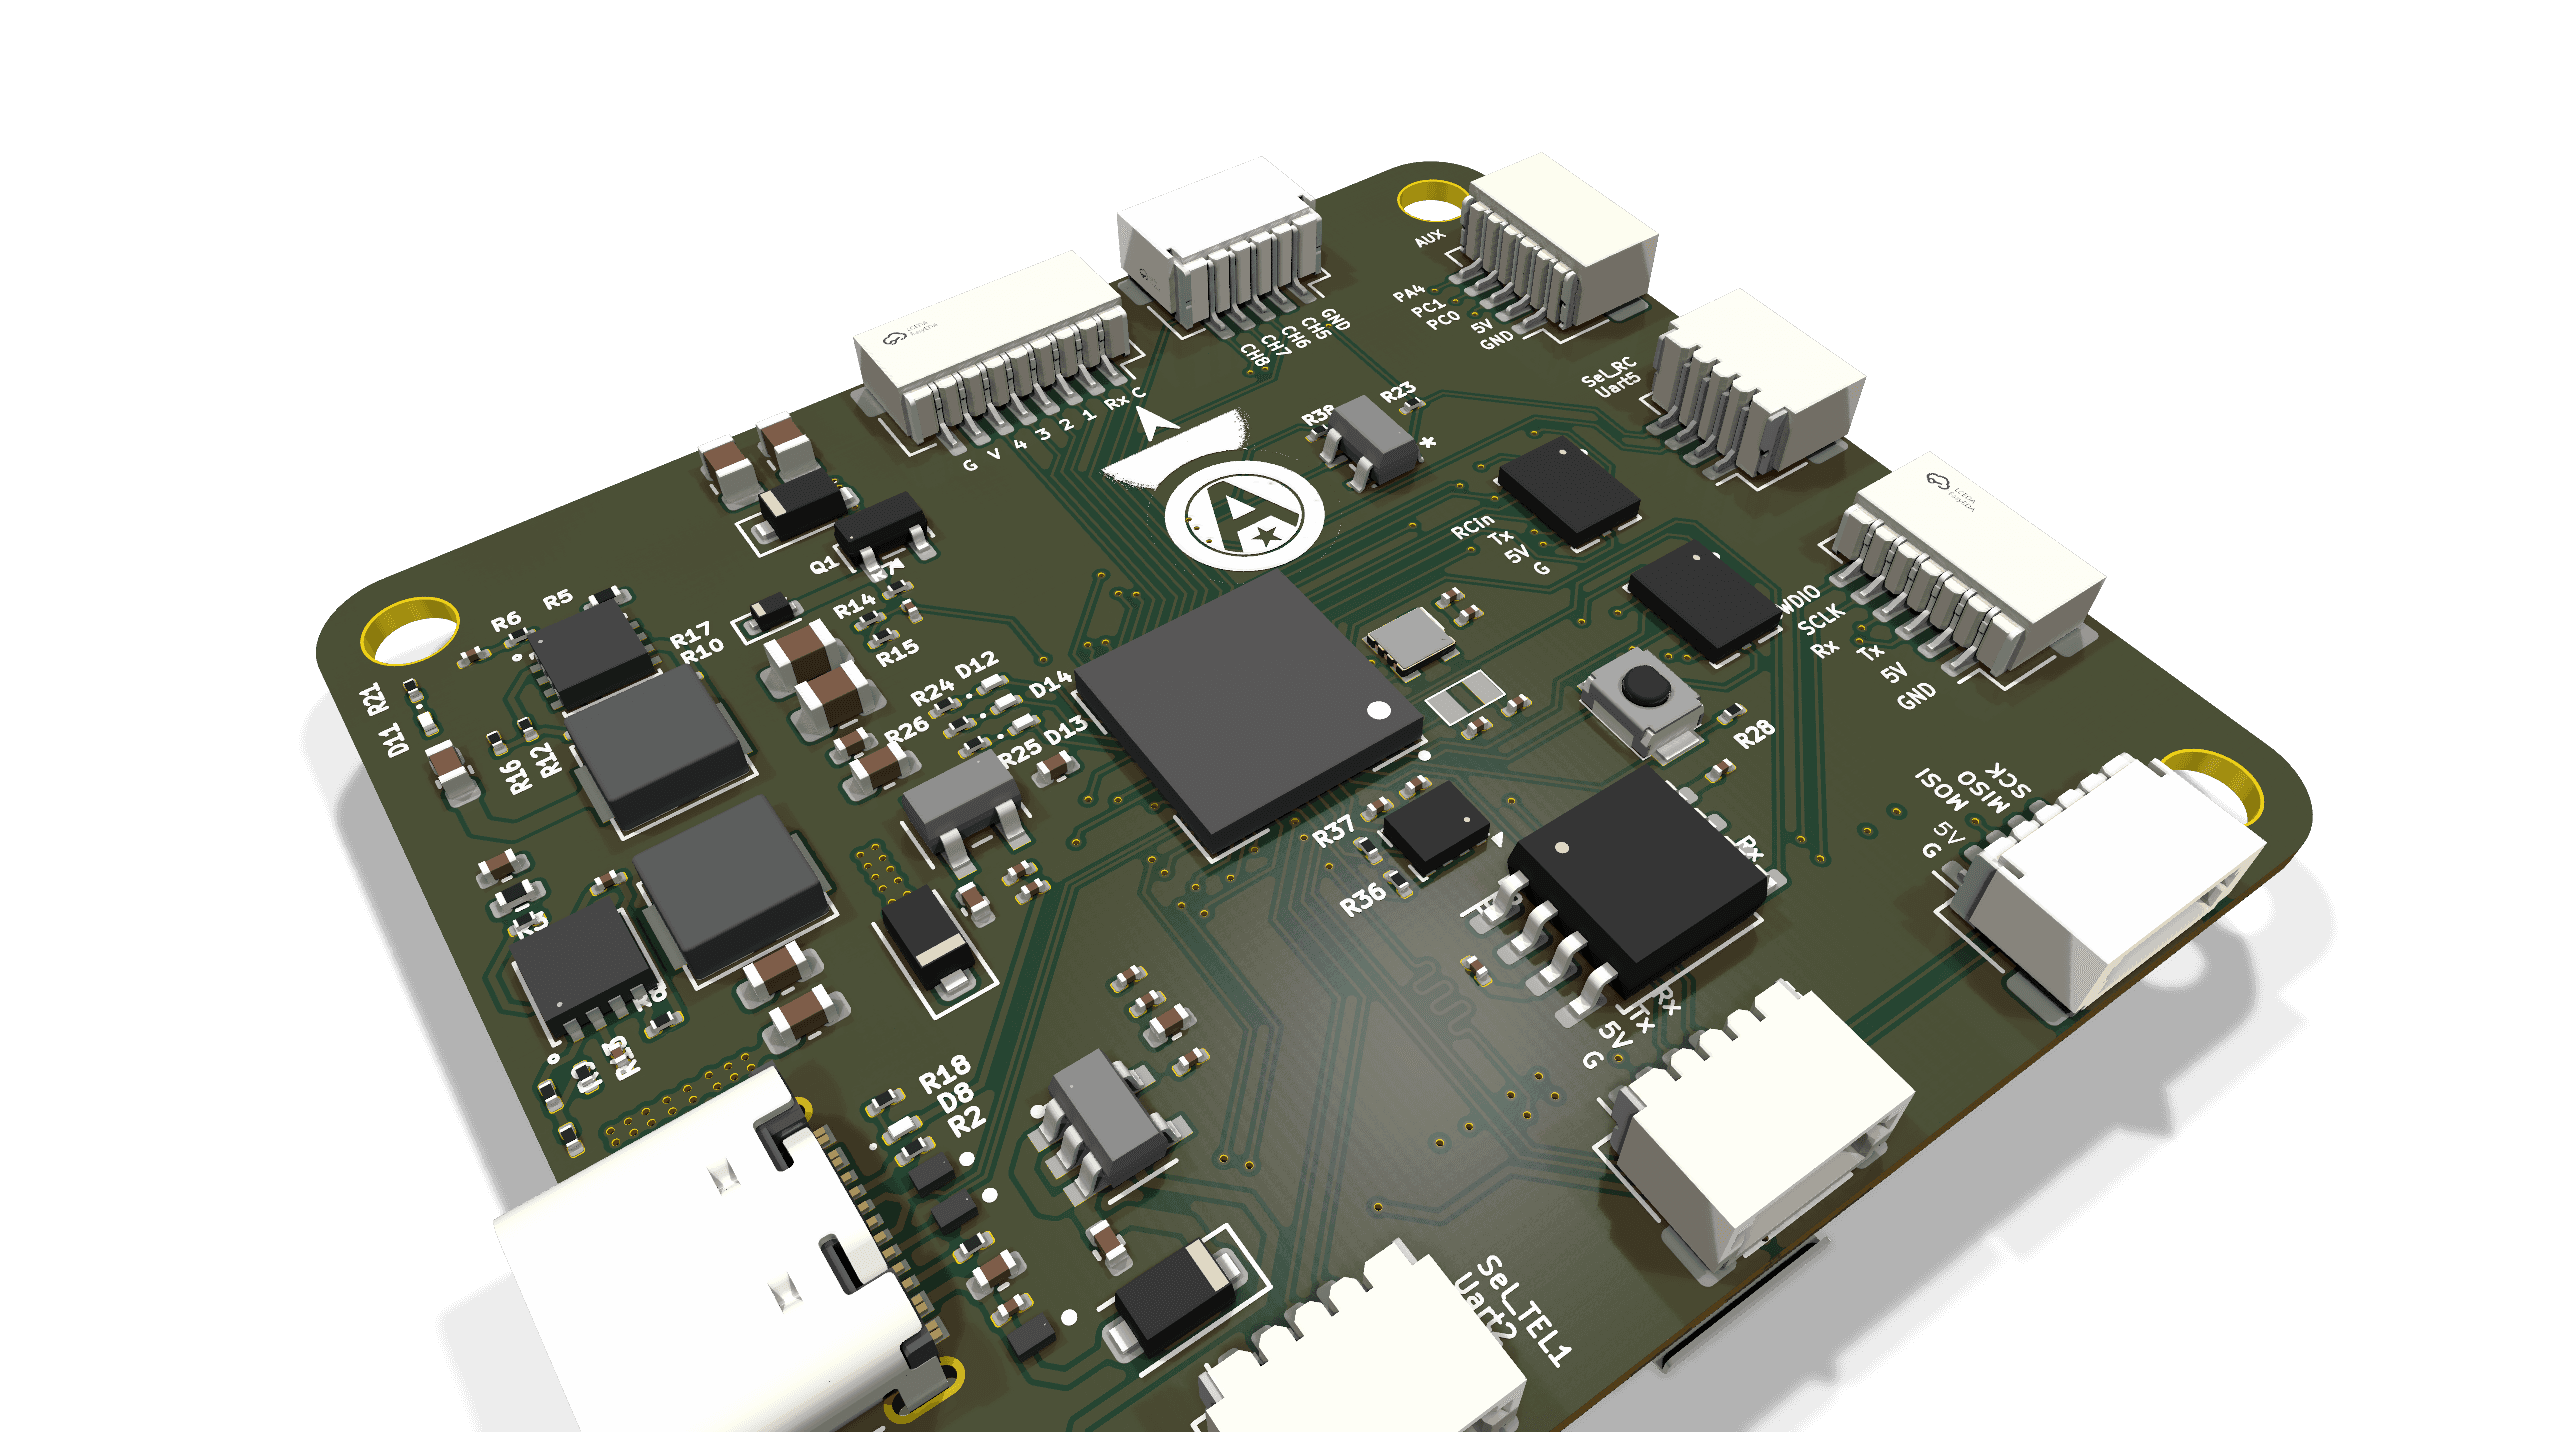
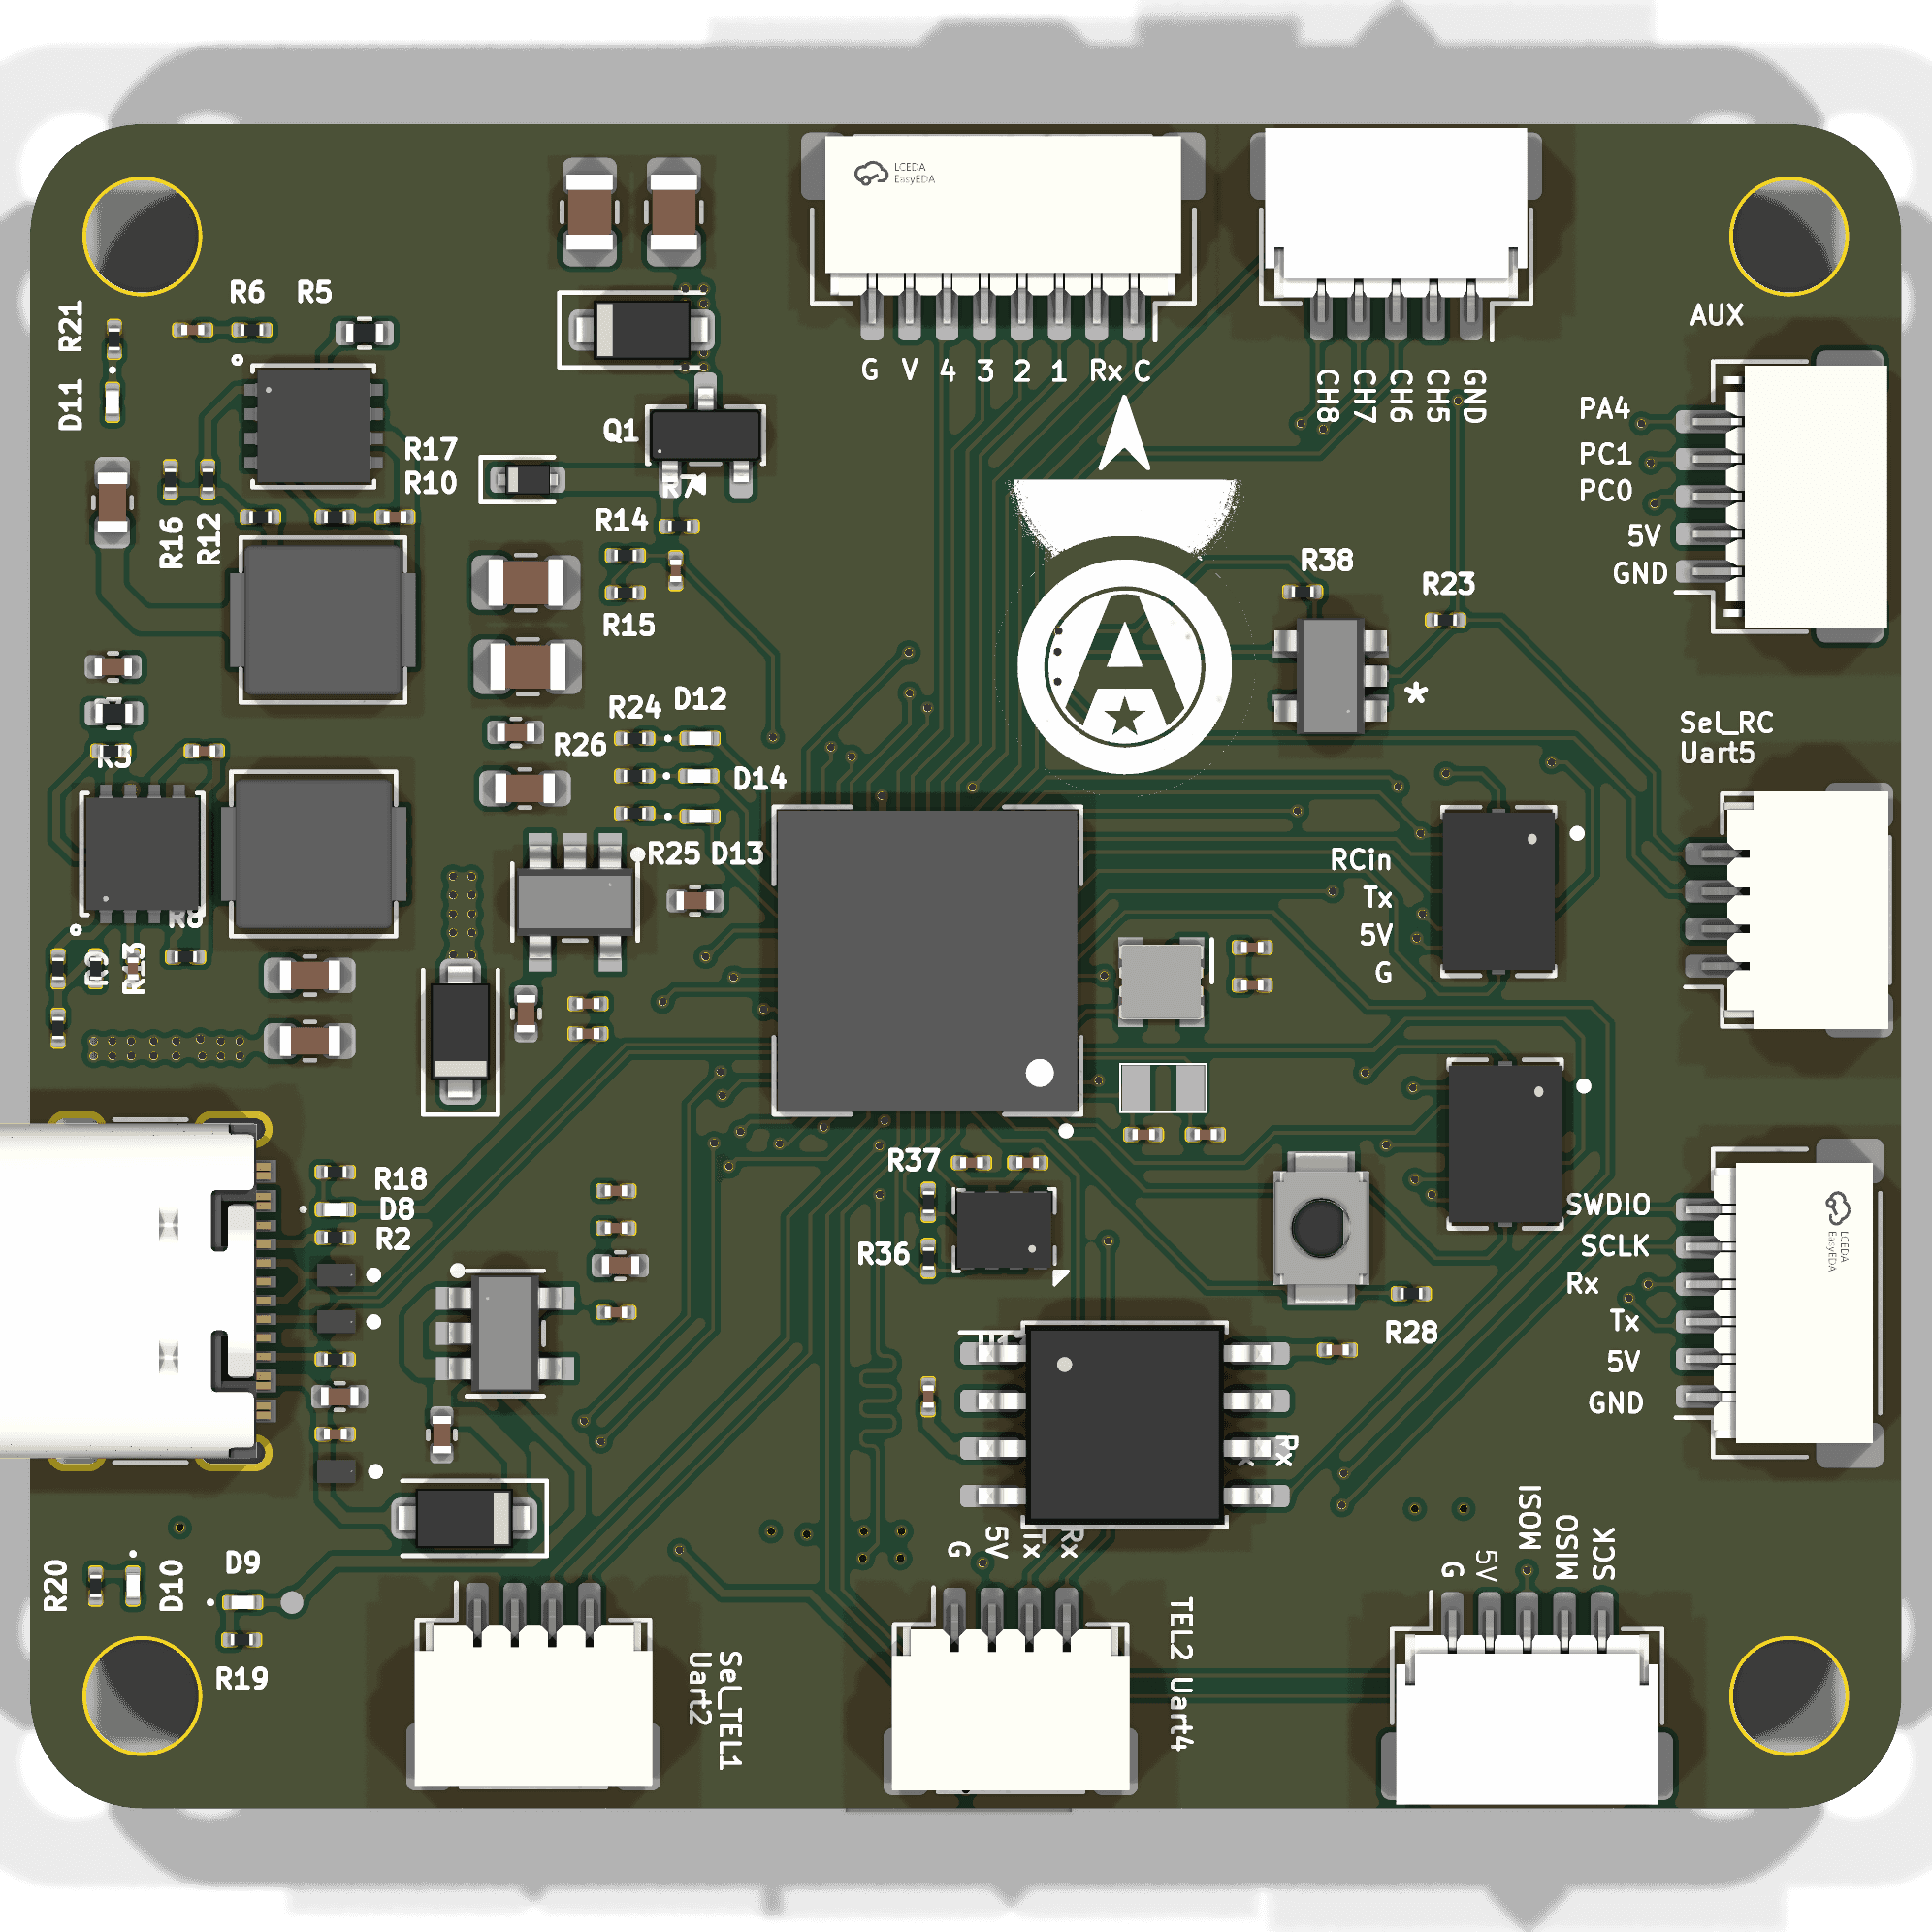
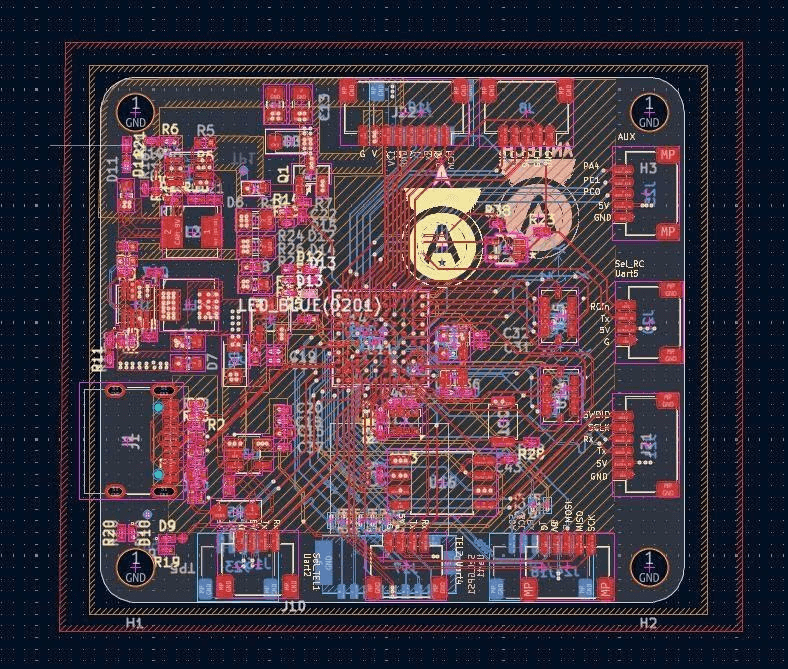
See the board at both product and PCB levels.
04 / Key specifications
The core hardware blocks.
- Processing
- STM32H743VIH6 · Cortex-M7 480 MHz · 2 MB Flash / 1 MB RAM
- Navigation
- 2 × Bosch BMI088 on independent SPI buses; SPL06-001 barometer
- Blackbox
- 16 MB SPI NOR Flash + MicroSD slot on 4-bit SDMMC
- Power
- 3S–6S LiPo; 5 V / 3 A and 9/12 V / 3 A rails
- Interfaces
- USB-C, 4-in-1 ESC, GPS/Compass, UART, SWD, DJI O3
- Mechanical
- 50 × 45 mm board; 30.5 × 30.5 mm M3 mounting
Open design, clear documentation
Explore the complete engineering package.
The public repository includes KiCad files, schematics, renders and fabrication outputs. Specifications here come from the project documentation; actual operational performance requires hardware testing.
Images & design: Minh An / AniTech · MIT License