
Project case study · Autonomous robotics
Hybrid Robot Pro / 2026
One robot. Two challenges. One control platform.
Hybrid Robot Pro combines Micromouse maze solving and Sumo combat on an ESP32-S3 platform. Its hardware, firmware and WebUI support sensor monitoring, motion tuning and rapid iteration.
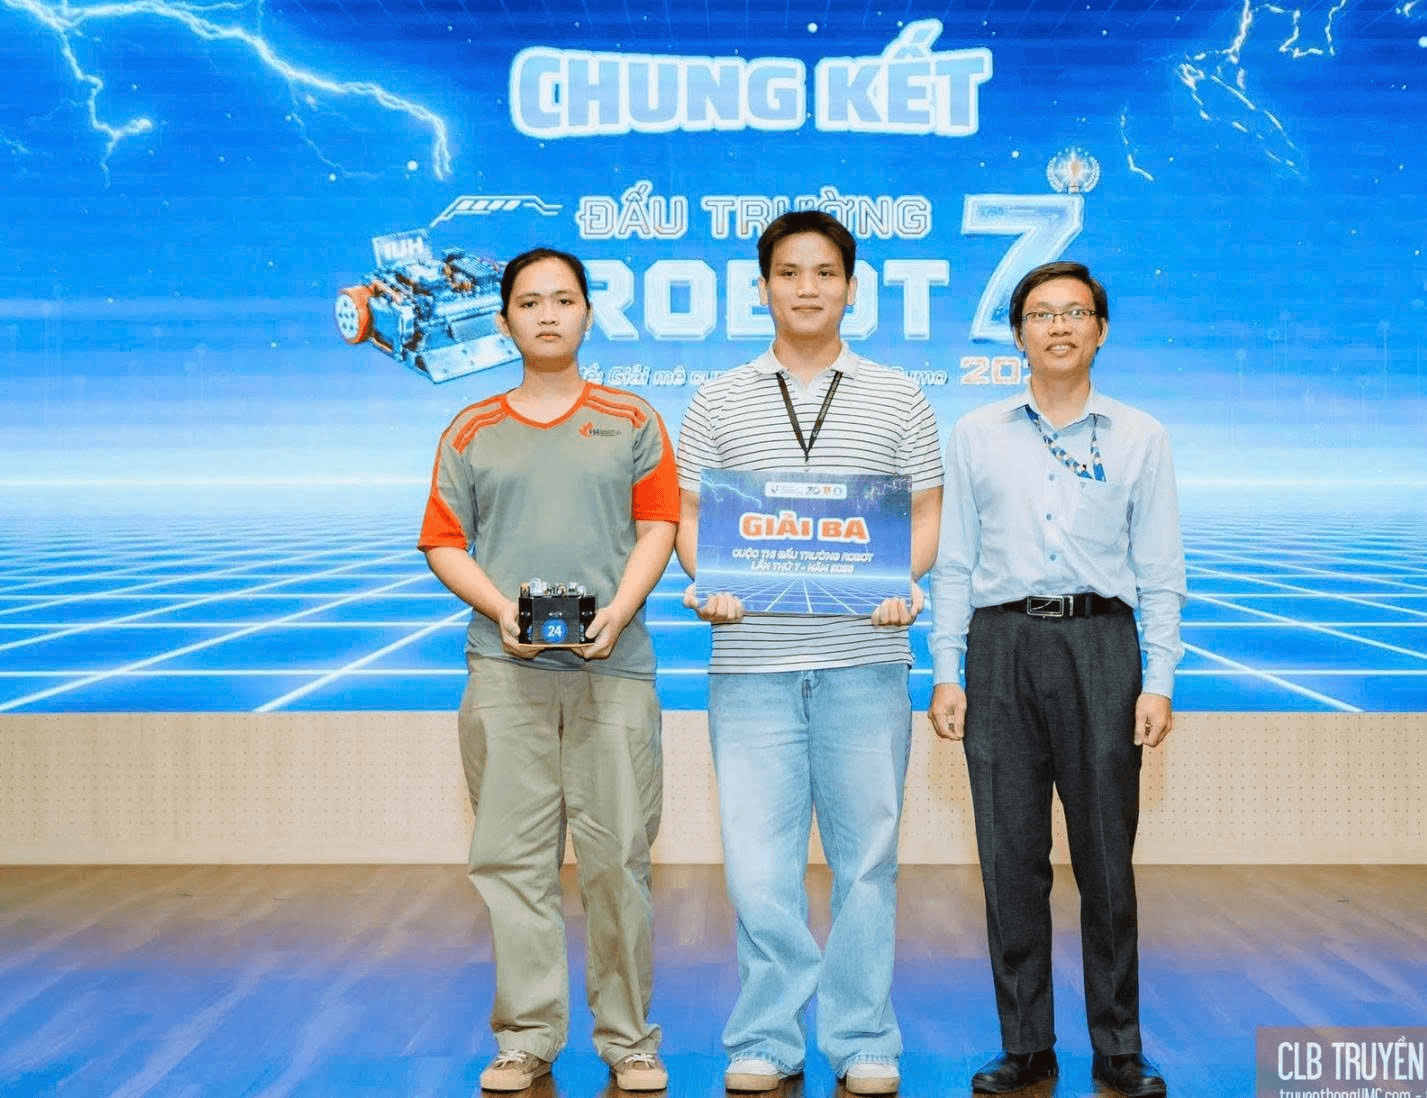
Third place · Robot Arena 7
Shown in an award photograph supplied by the project owner
02
Micromouse & Sumo
05
Multi-directional ranging
ESP32-S3
Control & Wi-Fi connectivity
WebUI
WebSocket · OTA
01 / The challenge
A single system that adapts to two kinds of motion.
Maze solving calls for wall detection, path recording and accurate motion. Sumo requires multi-directional opponent detection and quick reactions. One controller coordinates sensors, encoders, motors and safe operating states.
02 / Engineering approach
From sensor readings to motion decisions.
Sensing
Five VL53L0X sensors measure distance; an MPU6050 assists with heading and turns.
Motion control
Two encoder-equipped DC motors; wall-following and velocity PID parameters can be tuned live.
Connectivity
A WebSocket WebUI streams readings, accepts start/stop commands, updates parameters and uploads firmware over the air.
03 / Physical prototype
Hardware built, assembled and taken into testing.
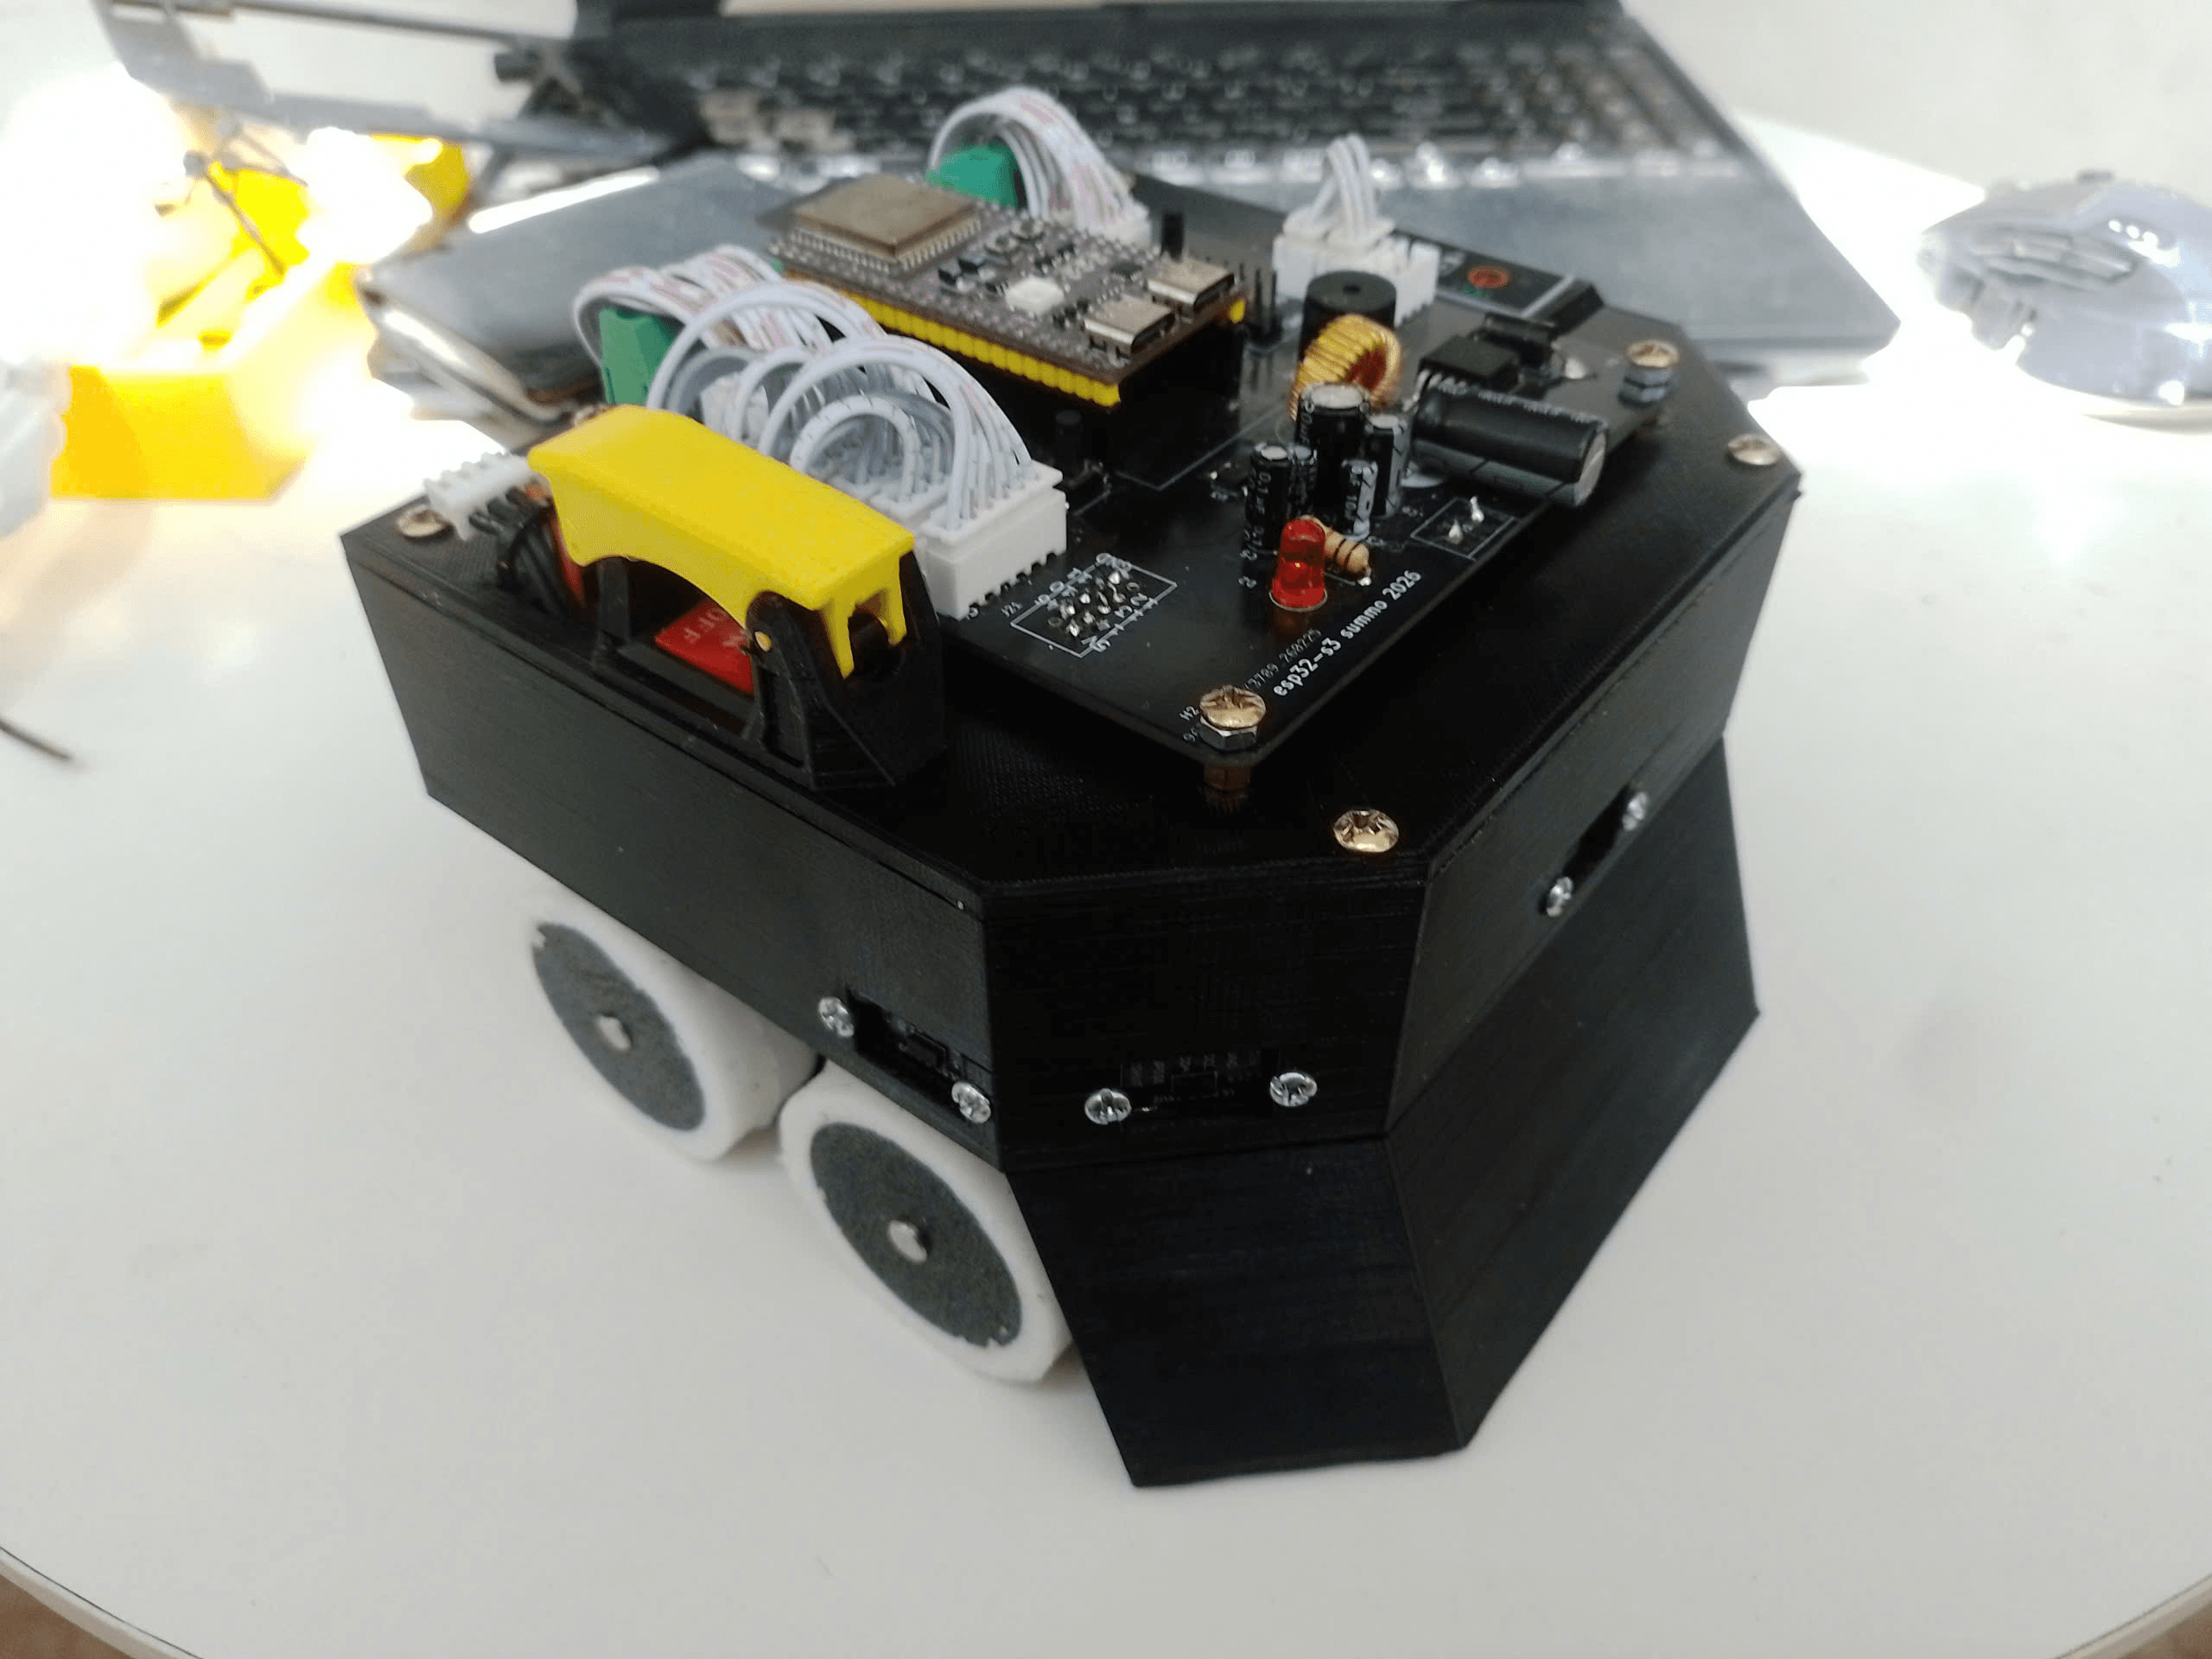
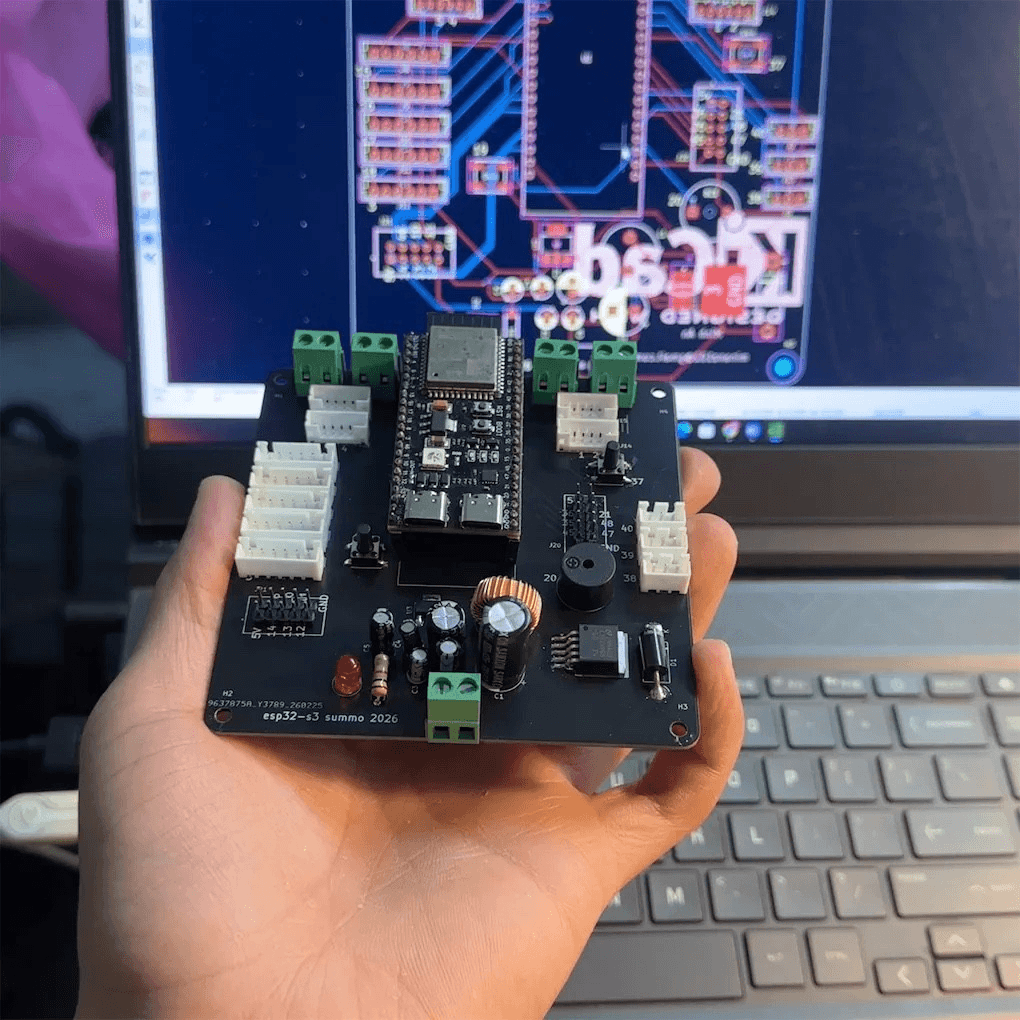
The photographs show the controller board, sensor connectors and assembled robot chassis. The supplied video demonstrates maze solving; the competition award is documented in a photograph.
04 / Video demonstration
Maze solving in action.
Watch the Micromouse demonstration on the AniTech channel. Sumo mode and WebUI capabilities are documented in the source repository.
Source code & development
Explore how the robot works.
The public GitHub repository includes Arduino/ESP32 firmware, sensor and motion modules, and the WebUI. Prototype and award photographs were provided by the project owner for this page.